


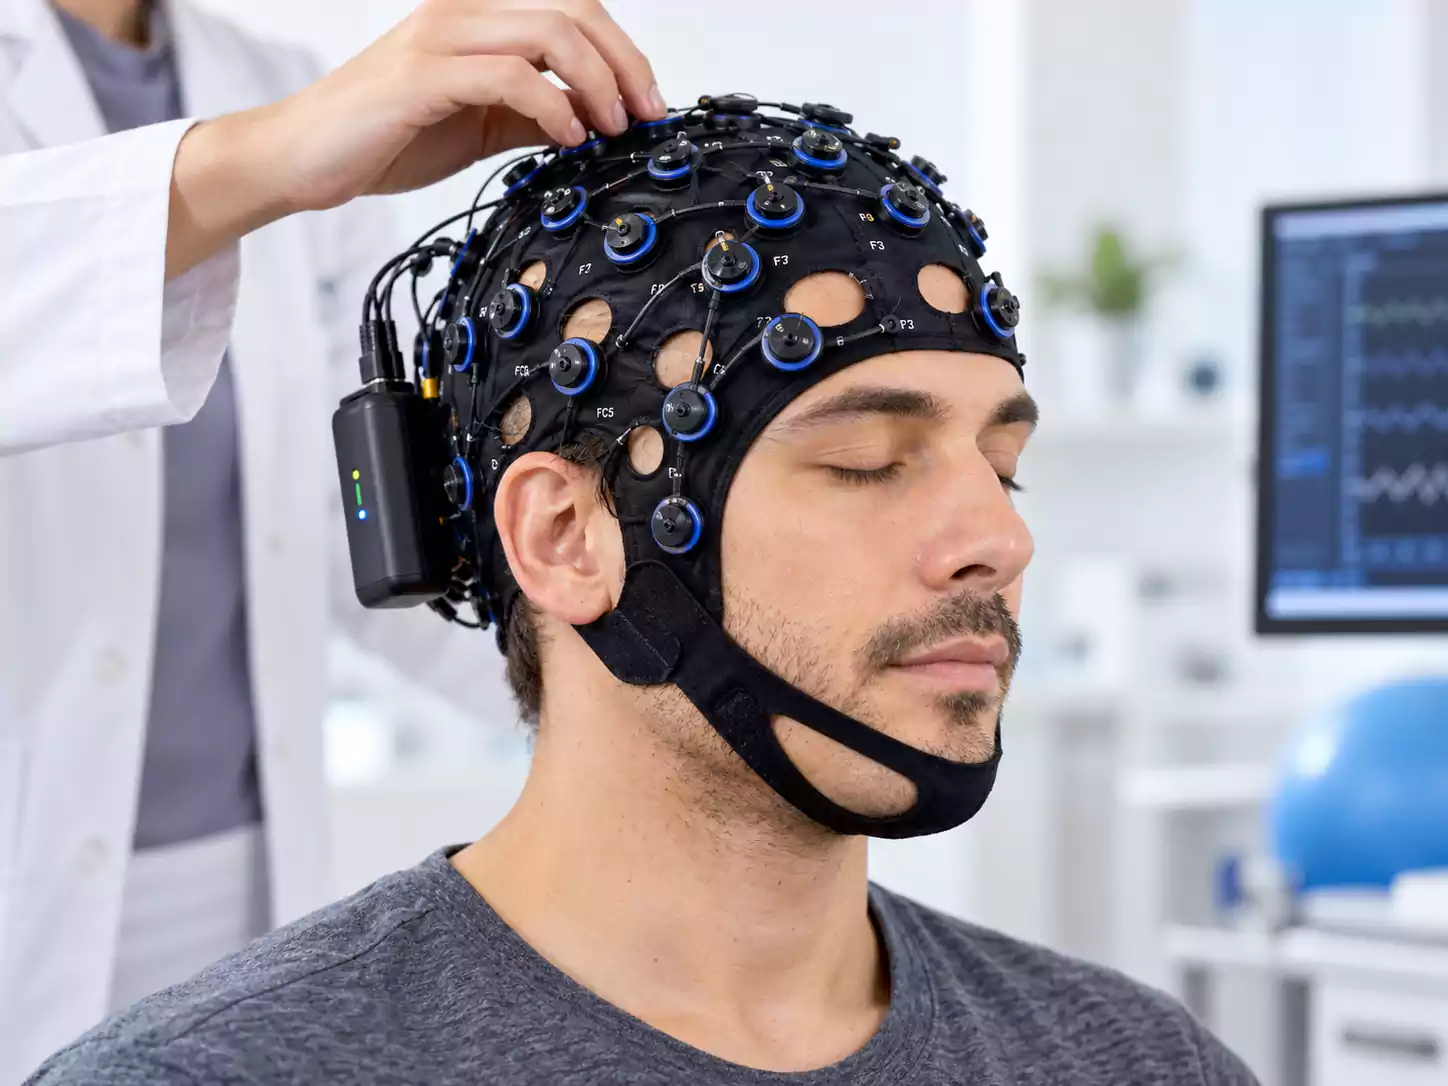
An EEG-controlled rehabilitation robot uses brain signals to detect movement intentions and translate them into assisted robotic motion. These systems combine electroencephalography (EEG), brain-computer interfaces (BCIs), motor controllers, and sensor feedback to support motor rehabilitation research, particularly for patients recovering from stroke or neurological injuries.
The engineering challenge is connecting sensitive EEG acquisition hardware with reliable robotic motion control. Microvolt-level brain signals are vulnerable to electrical noise, while motor drivers, switching power supplies, and communication delays can affect system performance.
This article explains how EEG-controlled rehabilitation robots work, how their electronic systems are integrated, and the PCB design and testing considerations that support reliable operation.
1. How Do EEG-Controlled Rehabilitation Robots Work?
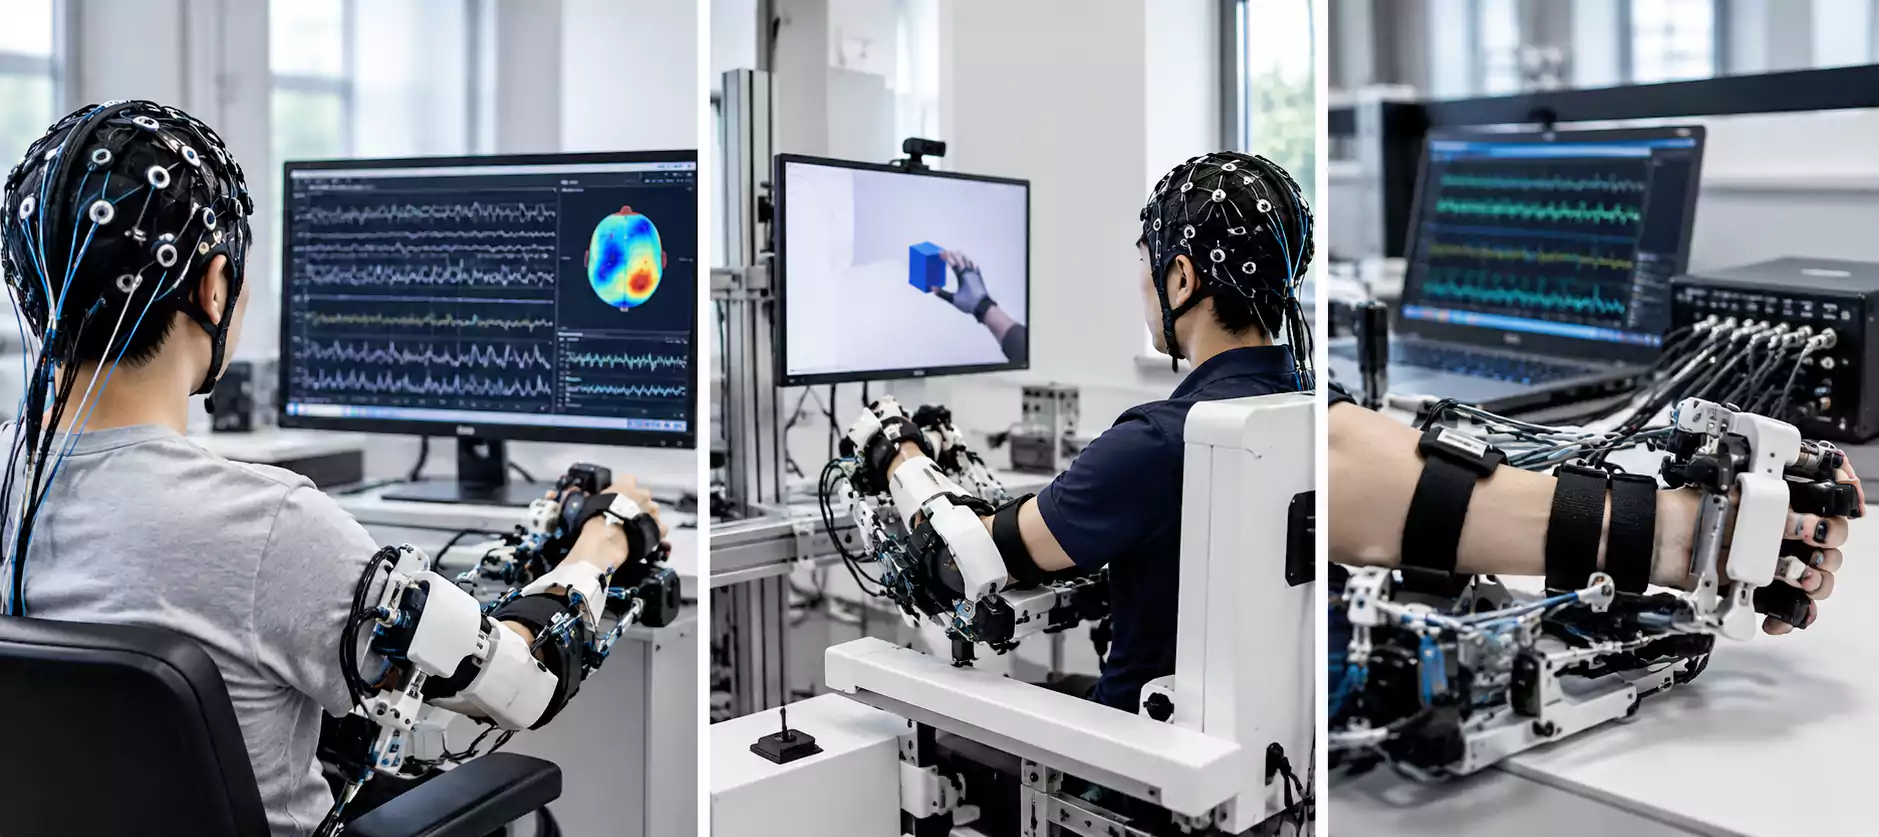
EEG-controlled rehabilitation robots use brain activity to initiate or influence assisted movements. One common approach is motor imagery (MI), in which a patient imagines a movement, such as opening a hand, without physically performing it.
Motor imagery produces changes in sensorimotor EEG rhythms, particularly in the mu and beta frequency bands. A BCI processes these patterns to recognize predefined movement intentions.
The control process typically follows five steps:
- EEG acquisition: Scalp electrodes capture electrical brain activity.
- Signal processing: An analog front end (AFE) amplifies and digitizes the signals, while processing algorithms extract relevant features.
- Movement classification: A processor uses trained classification algorithms to identify the intended movement.
- Motion control: The system sends valid commands to a robotic controller, which drives the appropriate actuator.
- Sensor feedback: Encoders, inertial sensors, and force sensors monitor movement and support closed-loop control.
For example, when a patient imagines opening a hand, the BCI may identify the corresponding EEG pattern and trigger a robotic hand orthosis to perform a controlled opening movement.
The BCI generates movement intentions or high-level commands, while a dedicated motor controller manages the physical movement.
2. Hardware Architecture and PCB Design
An EEG-controlled rehabilitation robot combines low-noise signal acquisition, embedded processing, motor control, and sensor feedback. Each subsystem has different electrical and PCB design requirements.

| Hardware module | Main components | Design considerations |
|---|---|---|
| EEG acquisition PCB | Electrodes, AFE, ADC | Low noise, input impedance, interference |
| BCI processing board | MCU, MPU, FPGA | Processing latency, synchronization |
| Motor control PCB | MCU, motor driver, MOSFET | PWM noise, current, thermal management |
| Sensor interface | Encoder, IMU, force sensor | Signal integrity, feedback accuracy |
| Power management | DC/DC, protection circuits | Supply noise, isolation, protection |
These modules can be integrated onto a shared PCB or distributed across multiple boards, depending on system size, electrical noise, and mechanical requirements.
EEG Signal Acquisition and Analog Front-End Design
EEG signals are typically measured in microvolts, so reliable acquisition requires low input-referred noise, high input impedance, and high common-mode rejection ratio (CMRR).
An EEG AFE such as Texas Instruments' ADS1299 integrates programmable gain amplifiers and simultaneous-sampling, 24-bit ADCs for multichannel biosignal acquisition.
Effective EEG PCB design must account for electrode contact impedance, input filtering, ADC reference stability, power-line interference, and channel synchronization.
Electrode connections and sensitive analog traces benefit from careful placement, controlled return paths, and protection from nearby switching circuitry.
Embedded Processing and Communication
After digitization, the embedded processor filters the data, extracts features, and classifies movement.
STM32 microcontrollers, higher-performance SoCs, and FPGAs offer different trade-offs in processing capability, power consumption, and timing performance.
Communication interfaces are selected according to their functions. SPI commonly connects an EEG AFE to a processor, while CAN, UART, or other suitable interfaces connect processing units and motor controllers. BLE can support wireless wearable modules when its latency and reliability characteristics meet system requirements.
Separating sensitive EEG acquisition from high-power motor control can simplify noise management, although communication timing and electrical interfaces still require careful design.
HDI and Rigid-Flex PCB Integration
Wearable EEG headsets and compact rehabilitation devices often have limited space for electronic components and wiring.
HDI PCBs can support high-density routing and fine-pitch components. Flexible and rigid-flex PCBs can accommodate curved housings, moving assemblies, and compact interconnections.
The design must also account for connector reliability, mechanical strain, bend radius, and repeated movement. Material and stackup selection should reflect the device's actual mechanical and electrical requirements.
3. PCB Noise and EMI Challenges in EEG-Controlled Robots
One of the biggest design challenges is maintaining EEG signal quality while motors and power electronics operate.
EEG acquisition involves microvolt-level signals, while motor drivers switch comparatively large currents and voltages. Electrical interference can distort measurements, affect signal classification, and reduce control reliability.
How Motor PWM and Power Noise Affect EEG Signals
Motor drivers typically use pulse-width modulation (PWM) to regulate motor output. MOSFET switching, motor currents, and DC/DC converters generate electrical noise that can couple into sensitive EEG circuits.
Common coupling paths include shared power and ground impedance, nearby signal traces, cables, and electromagnetic radiation.
In a study titled Development of EEG Brain-Computer Interface System for Control of Shoulder-Elbow Rehabilitation Robot, researchers reported EEG interference associated with their integrated control arrangement. By separating EEG processing and robotic control functions and improving signal processing, they improved acquisition performance.
This shows the importance of addressing interference at both the PCB and system-architecture levels.
PCB Layout, Grounding, and Shielding
Effective PCB design focuses on controlling interference sources and their coupling paths.
- Component placement: Position EEG analog front-end circuitry away from motor drivers, switching regulators, and high-current traces. Sensitive input connections benefit from short, carefully routed signal paths.
- Grounding and return paths: Provide appropriate reference planes and control return-current flow. A well-planned ground structure helps reduce common-impedance coupling between sensitive analog circuits and power electronics.
- Power integrity: Use suitable decoupling, filtering, and power distribution. Keep high-current switching loops compact to reduce noise emissions.
- Shielding and signal routing: Use shielded cables, differential signaling where appropriate, and physical separation to reduce interference. Patient-connected circuitry may also require electrical isolation based on the system's safety architecture.
The goal is to maintain reliable signal acquisition during actual robotic operation, not just optimize PCB noise performance under laboratory conditions.
Testing EEG Signal Quality During Motor Operation
EEG performance should be evaluated under representative operating conditions, including:
- Motors disabled and enabled.
- Different motor speeds and mechanical loads.
- Power supplies and communication modules switching.
- Electrode movement and changing contact conditions.
Engineers can compare input-referred noise, signal spectra, saturation events, and classification performance across these conditions.
This helps identify whether interference originates from PCB power distribution, motor switching, electrode contact, cable routing, or movement artifacts.

4. Real-Time Motor Control, Feedback, and Safety
Reliable robotic assistance requires accurate movement-intention detection and predictable motor control.
These processes operate on different time scales. EEG classification depends on signal-processing windows, while motor controllers use sensor feedback to regulate movement at faster, application-specific rates.
Reducing EEG-to-Motion Latency
The total response time includes several stages:
Total latency = EEG acquisition + Signal processing + Communication + Motor control + Actuator response
EEG classification windows and processing algorithms can contribute substantially to overall latency.
Developers should evaluate processing time, communication performance, command validation, and mechanical response together.
Local embedded processing can reduce dependence on network connections and provide more predictable communication paths.
The appropriate design balances classification accuracy, response time, power consumption, and motion safety.
Closed-Loop Motor Control and Sensor Feedback
After receiving a valid BCI command, the robot controller uses feedback to execute the intended movement.
Encoders measure position, while current sensors or force or torque sensors help regulate mechanical interaction. Feedback allows the controller to adjust position, speed, or assistance force within predefined limits.
Some systems combine EEG with electromyography (EMG). EEG provides information about brain activity, while EMG reflects muscle activation.
This combination can provide complementary control information, but its effectiveness depends on synchronized acquisition, signal quality, and individual patient capabilities.
Reliable integration of motor drivers, controllers, and feedback sensors is also key to manufacturing rehabilitation robot PCBAs.
Safe Motion Control
EEG signals vary between users and recording sessions, so movement classification includes uncertainty.
A reliable controller evaluates command confidence and handles invalid signals, communication timeouts, and sensor faults through defined safety responses.
Position, speed, and force limits help constrain assisted movement. Independent emergency-stop and protection mechanisms provide additional safeguards.
These functions require system-level verification based on the intended clinical application and device risk assessment.
5. PCB Assembly, Functional Testing, and Medical Reliability
Moving from a laboratory prototype to repeatable production requires consistent PCB manufacturing, component assembly, and electrical performance.
EEG acquisition boards contain sensitive analog circuits, while motor controllers introduce power, thermal, and connector requirements. Both must perform reliably after assembly and system integration.
PCB Assembly and Manufacturing Requirements
Design for Manufacturability (DFM) and Design for Testability (DFT) reviews help identify layout, assembly, and test-access issues before production.
Fine-pitch components, precision analog ICs, and complex packages require controlled SMT processes.
Solder paste inspection (SPI), automated optical inspection (AOI), and X-ray inspection support manufacturing quality by detecting different types of assembly defects.
BOM control, PCB revision management, and component traceability help maintain production consistency.
Functional Testing of EEG and Motor Control PCBs
Functional testing should evaluate individual electronic modules and how they interact within the complete system.
| Test | Verification focus |
|---|---|
| EEG acquisition | Input response, noise, channel consistency |
| Motor driver | PWM output, current sensing, protection |
| Sensor feedback | Encoder, IMU, force-sensor response |
| Communication | Data integrity, timing, error handling |
| EMI evaluation | EEG performance during motor operation |
| Fail-safe testing | Fault response, timeout, safe stopping |
Calibrated EEG-equivalent input signals can verify acquisition channels, while motor-driver testing evaluates outputs and protection functions under representative conditions.
Integrated testing should confirm that the EEG processor, communication interfaces, motor controller, and sensors operate together reliably.
For medical device development, ISO 13485 quality management processes can support manufacturing control and traceability. Applicable IEC 60601 requirements and system-level risk management guide electrical safety and essential performance verification.
Early DFM and test planning help reduce redesign during engineering validation, NPI, and pilot production—an important consideration in medical device PCB assembly.
6. Frequently Asked Questions
Can EEG signals directly control a rehabilitation robot?
EEG signals are processed to identify predefined movement intentions. The BCI converts these results into control commands, while a robotic controller manages actuator movement using sensor feedback and safety limits.
How does motor interference affect EEG acquisition?
PWM switching, motor currents, and power converters can introduce electrical noise through power distribution, return paths, cables, and electromagnetic coupling. Appropriate PCB layout, filtering, shielding, and testing under operating conditions help manage these effects.
How can latency be reduced in EEG-controlled rehabilitation robots?
Developers can optimize EEG processing windows, embedded algorithms, communication interfaces, and controller scheduling. Evaluate response time across the full acquisition-to-motion pathway while maintaining classification reliability and safe movement.
Conclusion
Reliable EEG-controlled rehabilitation robots depend on integrating low-noise brain-signal acquisition, embedded processing, motor control, and sensor feedback.
Careful PCB design, interference management, and functional testing help developers address these challenges as systems progress from research prototypes toward practical medical devices.
MULTIPCB supports medical electronics development with precision PCB fabrication, HDI and rigid-flex PCB manufacturing, SMT assembly, and turnkey PCBA services from prototyping through production.
